🔍 Read the full analysis: Inside NVIDIA Cosmos3-H-Dreams And Its Generative Simulation Of Clinical Surgery on ThorstenMeyerAI.com

Get the latest gadgets delivered free with Prime
- Fast, free delivery on millions of items
- Prime Video, Amazon Music and more included
- Member-only deals all year
TL;DR
NVIDIA has introduced Cosmos3-H-Dreams, a generative simulator trained on clinical cholecystectomy video and robot-control data from CMR Surgical’s Versius platform. NVIDIA says it responds to live instrument controls and runs interactively on one RTX PRO 6000 GPU; the supplied material gives no independent validation, measured speed or evidence of clinical suitability.
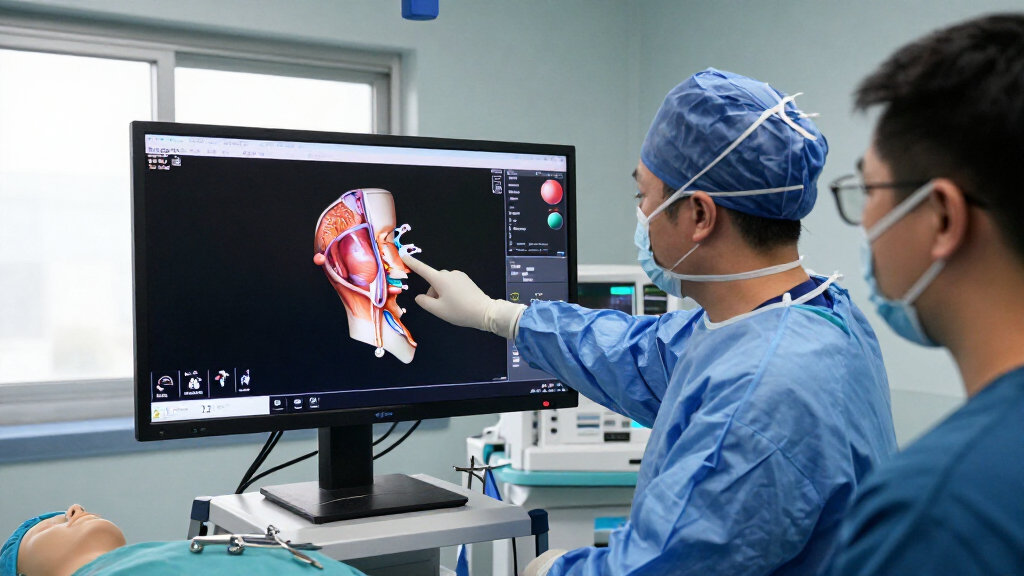
NVIDIA has introduced Cosmos3-H-Dreams, a generative simulator that creates surgical video in response to instrument actions, trained on clinical gallbladder-removal footage and robot kinematics from CMR Surgical’s Versius platform. NVIDIA says it supports live control and runs interactively on a single RTX PRO 6000 GPU, but the available announcement does not establish that its output is biomechanically accurate or suitable for clinical training or decisions.
The model learns from synchronized surgical video and robot kinematics, rather than explicitly computing anatomy, tissue deformation and instrument contact through a conventional numerical simulation. Given a starting scene and control inputs, it generates subsequent video frames that reflect the actions. The training footage focuses on two instruments: a left Cadiere grasper and a right monopolar hook.
NVIDIA describes a 28-dimensional action representation that includes the poses and gripper information for both arms, energy controls and thumbstick inputs. Training video is 832 by 480 pixels, and the actions are aligned at 10 Hz. That rate describes the alignment of training data; it is not a reported video-generation frame rate. The announcement provides no measured latency or benchmark for interactive speed.
Cosmos3-H-Dreams is built on Cosmos3-H-Embodied-Nano, a 16-billion-parameter model pretrained on Open-H-Embodiment and then adapted with selected cholecystectomy footage and control data. NVIDIA describes two student checkpoints: one using four denoising steps per video block and a separately trained two-step version intended to generate faster, with lower visual quality as a tradeoff. The system uses FlashDreams for streaming inference and an adapted FadeMem module to manage attention history during longer rollouts.
A New Test for Surgical Simulation
Generating scenes in response to instrument controls could give researchers and surgical-robot developers a way to explore possible actions without relying only on hand-built numerical models. The move from tabletop suturing demonstrations to footage of clinical cholecystectomy also tests whether this approach can handle visually complex scenes, including moving tissue, reflections, occlusion and smoke.
But a convincing image is not the same as a reliable simulation. For the system to support research or training, generated changes would need to follow the controls and preserve anatomy over time in ways that match real procedures. The supplied material offers no evidence that this has been established. At present, the announcement describes a research capability, not a validated clinical tool.
As an affiliate, we earn on qualifying purchases.
From Suturing to Gallbladder Surgery
Cosmos3-H-Dreams extends NVIDIA’s earlier Cosmos-H-Dreams work, which used Cosmos-Predict2.5 for interactive tabletop suturing with a dVRK setup. The new system applies the approach to clinical cholecystectomy recordings—procedures to remove the gallbladder—paired with robot kinematics so the model can learn how scenes change alongside instrument movement.
According to NVIDIA’s description, training involved first adapting a bidirectional teacher model on 24 future frames, then extending it to 72 frames, or 7.2 seconds at the training data’s 10 Hz action-alignment rate. The teacher was distilled into a causal student that generates video in short blocks as actions arrive. NVIDIA says training methods include causal teacher forcing and Self-Forcing, which exposes the model to its own generated context. These details describe the model’s development; they do not amount to a reported evaluation against real surgical outcomes.
““Visual realism is therefore a starting point for validation, not proof of biomechanical accuracy.””
— NVIDIA, in the Cosmos3-H-Dreams announcement
Accuracy and Testing Still Open
The supplied announcement reports no independent validation study, clinical evaluation, measured latency, frame rate or failure rate. It does not quantify how closely generated tissue movement matches biomechanical measurements, whether anatomy remains stable during longer sessions, or how the model behaves when given actions unlike those in its training data.
It is also unclear whether the system has been assessed for surgical education, robot development, preoperative planning or patient-facing use. NVIDIA’s statement that the system runs interactively on one RTX PRO 6000 GPU does not specify the response time, so it is not possible to judge how it would perform in particular workflows. The source does not describe safeguards against users mistaking plausible-looking but incorrect video for a reliable simulation.
Validation Before Practical Use
The next evidence needed is a documented evaluation comparing generated scenes with real surgical recordings and, where relevant, measurements of tissue motion and instrument effects. Such testing would need to address accuracy over time, response speed, failure cases and performance on unfamiliar actions, rather than relying on visual demonstrations alone.
The supplied announcement does not set out a validation timetable or identify a planned clinical study. Until more results are reported, Cosmos3-H-Dreams should be understood as a generative research system whose potential applications remain unconfirmed, rather than as an established training or decision-support tool.
Key Questions
What is NVIDIA Cosmos3-H-Dreams?
It is a generative surgical simulator that produces video in response to instrument actions. NVIDIA says it was trained on clinical cholecystectomy footage and robot kinematics from CMR Surgical’s Versius platform.
Does the system model tissue mechanics directly?
According to NVIDIA’s description, it learns visual patterns from paired video and robot-control data instead of explicitly calculating scene geometry and tissue mechanics through a numerical simulation.
Has its biomechanical accuracy been validated?
The supplied material reports no independent validation or measurements showing that generated tissue movement matches real biomechanical behavior. NVIDIA says visual realism is not proof of biomechanical accuracy.
How fast does Cosmos3-H-Dreams generate video?
NVIDIA says it runs interactively on a single RTX PRO 6000 GPU, but the announcement gives no measured latency or frame rate. The 10 Hz figure refers to training-data action alignment, not generation speed.
Is it ready for surgical training or clinical use?
The supplied announcement does not establish suitability for surgical education, clinical decisions or patient care. Those uses would require evaluations that are not reported in the material.
Primary source: Hugging Face · via ThorstenMeyerAI.com
Fall Picks
fall essentials
As an affiliate, we earn on qualifying purchases.